All projects / Vacuum gripper system VGS1
Vacuum gripper system VGS1
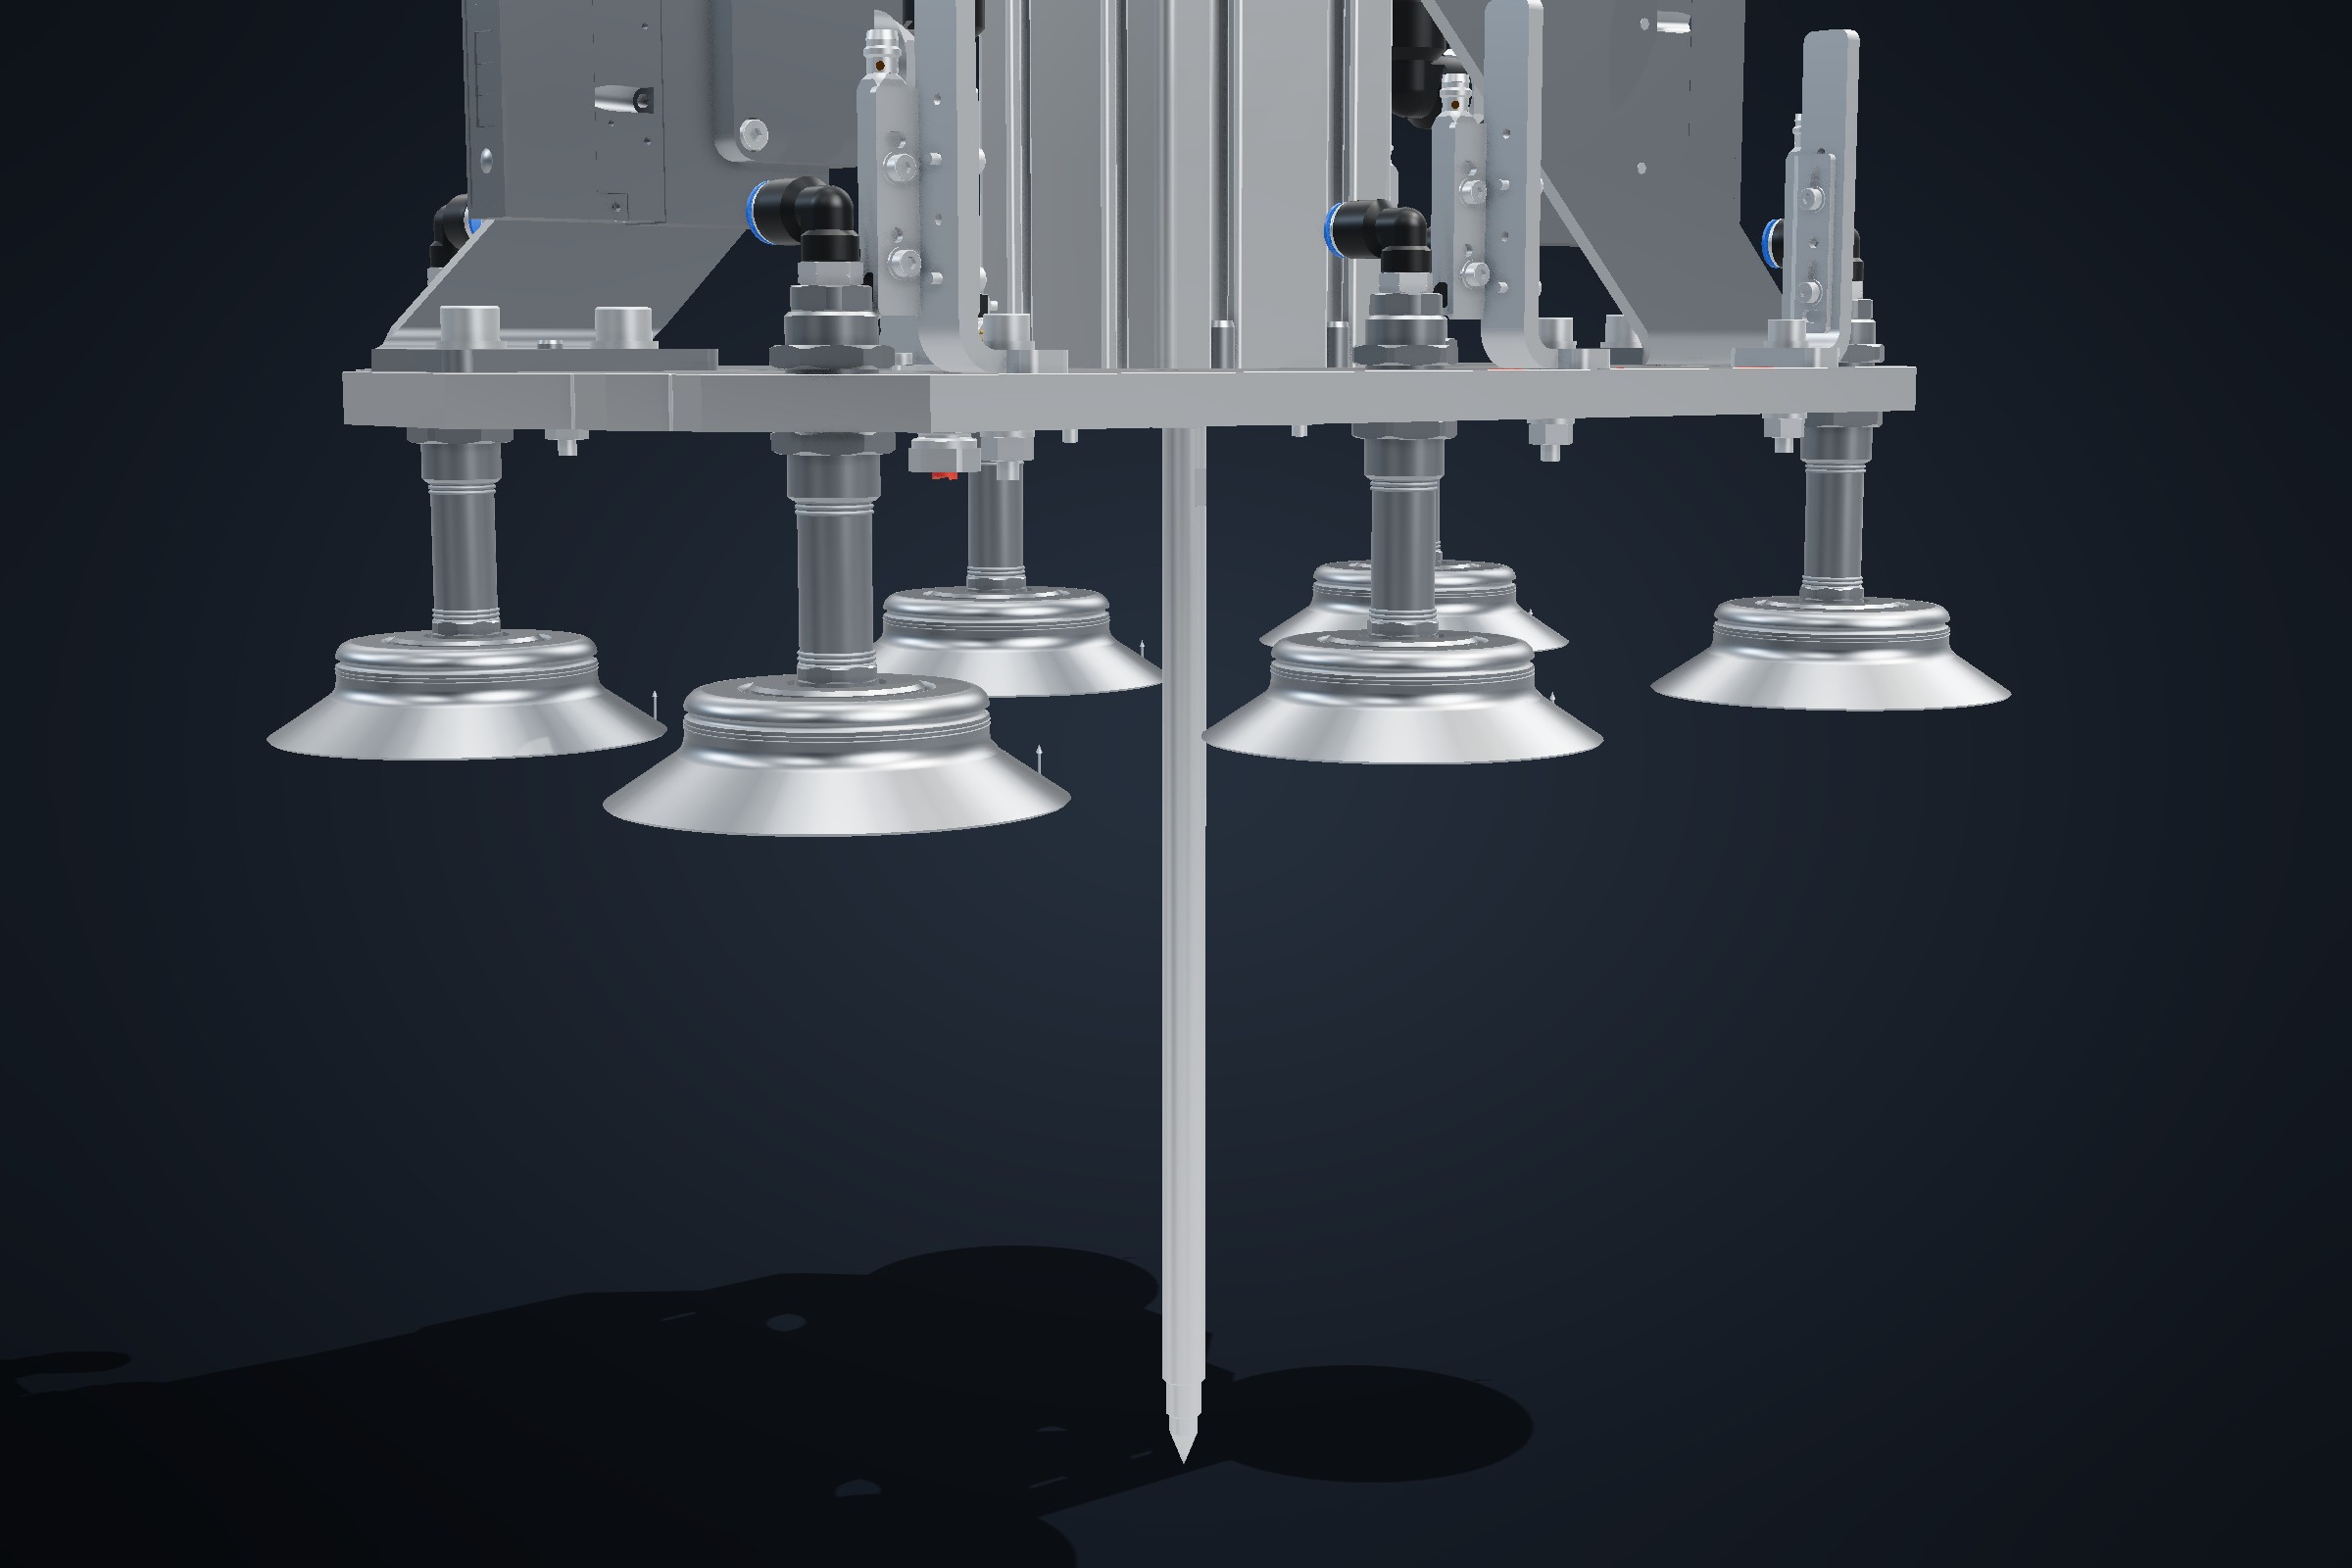
Vacuum gripper for robots, with spring-loaded suction cups and full IO-Link monitoring.
- Industry
- Robotics / handling
- Scope
- Design, pneumatics and sensor layout, documentation
- Sensors
- Part detection and vacuum monitoring via IO-Link

Starting point
Flat parts have to be picked and placed reliably by the robot, even when they are slightly warped. Mis-picks must be detected before a part drops.
Solution
A vacuum gripper with spring-loaded suction cups. The spring plungers compensate for height differences, so every cup seals properly.
Part presence, end positions and vacuum are monitored by sensors on an IO-Link module directly on the gripper, so only one cable runs to the controller. Pneumatics and fittings are easy to reach for service.
Result
- Reliable gripping even of warped parts
- Mis-picks are detected before a part drops
- One cable to the controller instead of many single wires