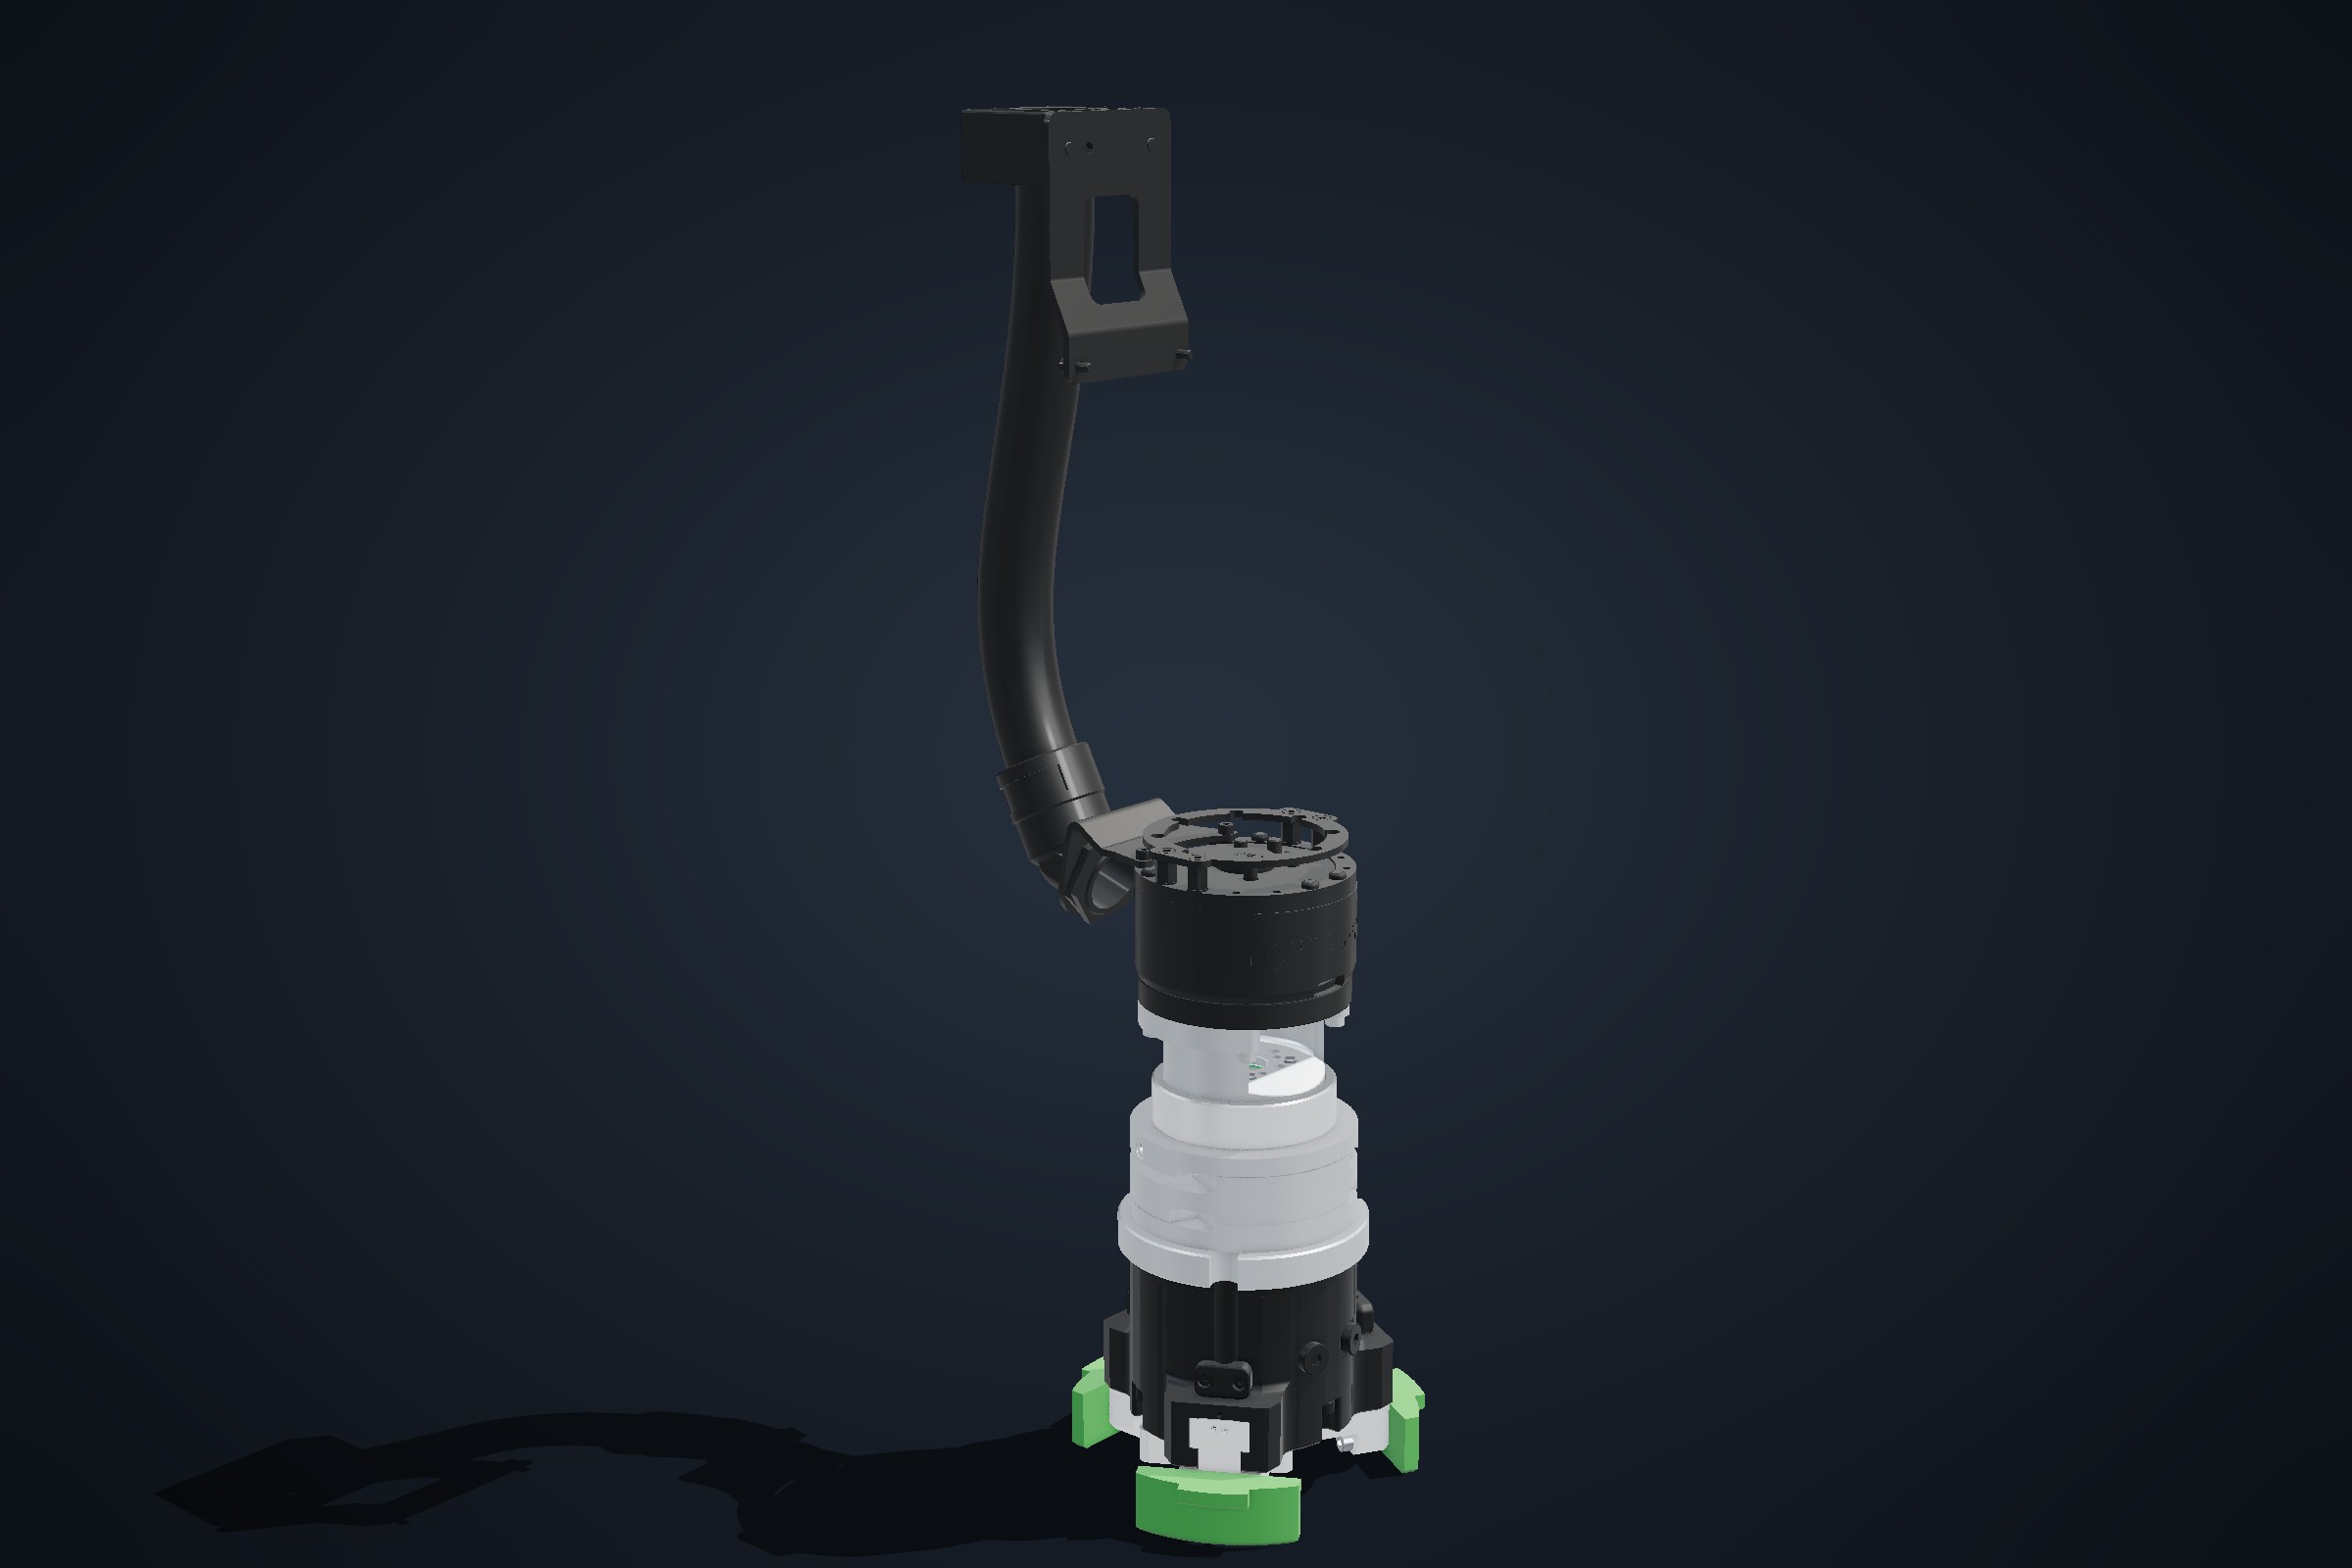
All projects / 3-point gripper system with compensation unit
3-point gripper system with compensation unit
Gripper system for round parts with three gripping points and a compensation unit, in two variants for different robots and media routings.
- Industry
- Robotics / machine tending
- Scope
- Design, adaptation, procurement
- Variants
- 2 (depending on robot and media routing)

Starting point
Round parts need to be gripped securely and centrically, even when their position varies slightly. The gripper system has to fit two different robots, each with its own media routing for air and signals.
Solution
A 3-point gripper system: three jaws with part-specific fingers centre the part by themselves. A compensation unit absorbs positional and angular deviations during picking and placing, so neither part nor gripper is strained.
Each variant has its own adapter plates and flange adapters. The media routing is laid out so that lines do not chafe during rotation.
Result
- Secure, centric gripping despite positional tolerances
- One gripper concept for two robots
- Part-specific fingers, quick to exchange